
叠放碗具
精细操作拿取、对齐,再稳稳叠放。
从拿取、放置到工具使用,以下真实任务均由统一的多核世界模型系统完成。
实机演示
拿取、对齐,再稳稳叠放。
拉开抽屉,将物品放入其中。
借助勺具,完成豆子的转移。
循环播放更多任务,悬停可停留观看。
一个统一的多核世界模型,让不同频率的核心协作,连接任务理解、世界状态预测与动作生成。
以较低频率理解任务目标,进行任务规划。
理解并预测世界状态,为下一步行动提供依据。
以较高频率生成动作,在真实任务中执行。
沿着同一轮浇花任务,看统一的多核世界模型如何将语言指令转化为行动。
从拿起水壶,
到完成浇灌。
Water the flowers
Global observationA small vase with white flowers sits on a red cloth on the table. The arm occludes the upper part of the background wall.
SideObservationThe arm's gripper is positioned above a red cloth on the table. A green object rests on the red cloth beneath the gripper. The arm base is mounted on the right side of the white table.
WristObservationA black laptop sits open on the white table in the lower left. A green and black curved object occupies the lower right foreground. A person in a striped shirt sits at the table with hands clasped.
Overall PlanMove the watering can toward the potted plant on the red cloth. Translate the arm forward to bring the watering can closer to the plant.
Arm Plan (Single Arm)Translate the arm forward to bring the watering can closer to the plant. Tilt the watering can to align the spout with the plant.
观察花盆、水壶与机械臂,并将语言指令展开为目标与动作规划。
结合相机视角与深度信息,理解物体之间的空间关系。
预测短时动作后的多视角画面,为下一步行动提供依据。
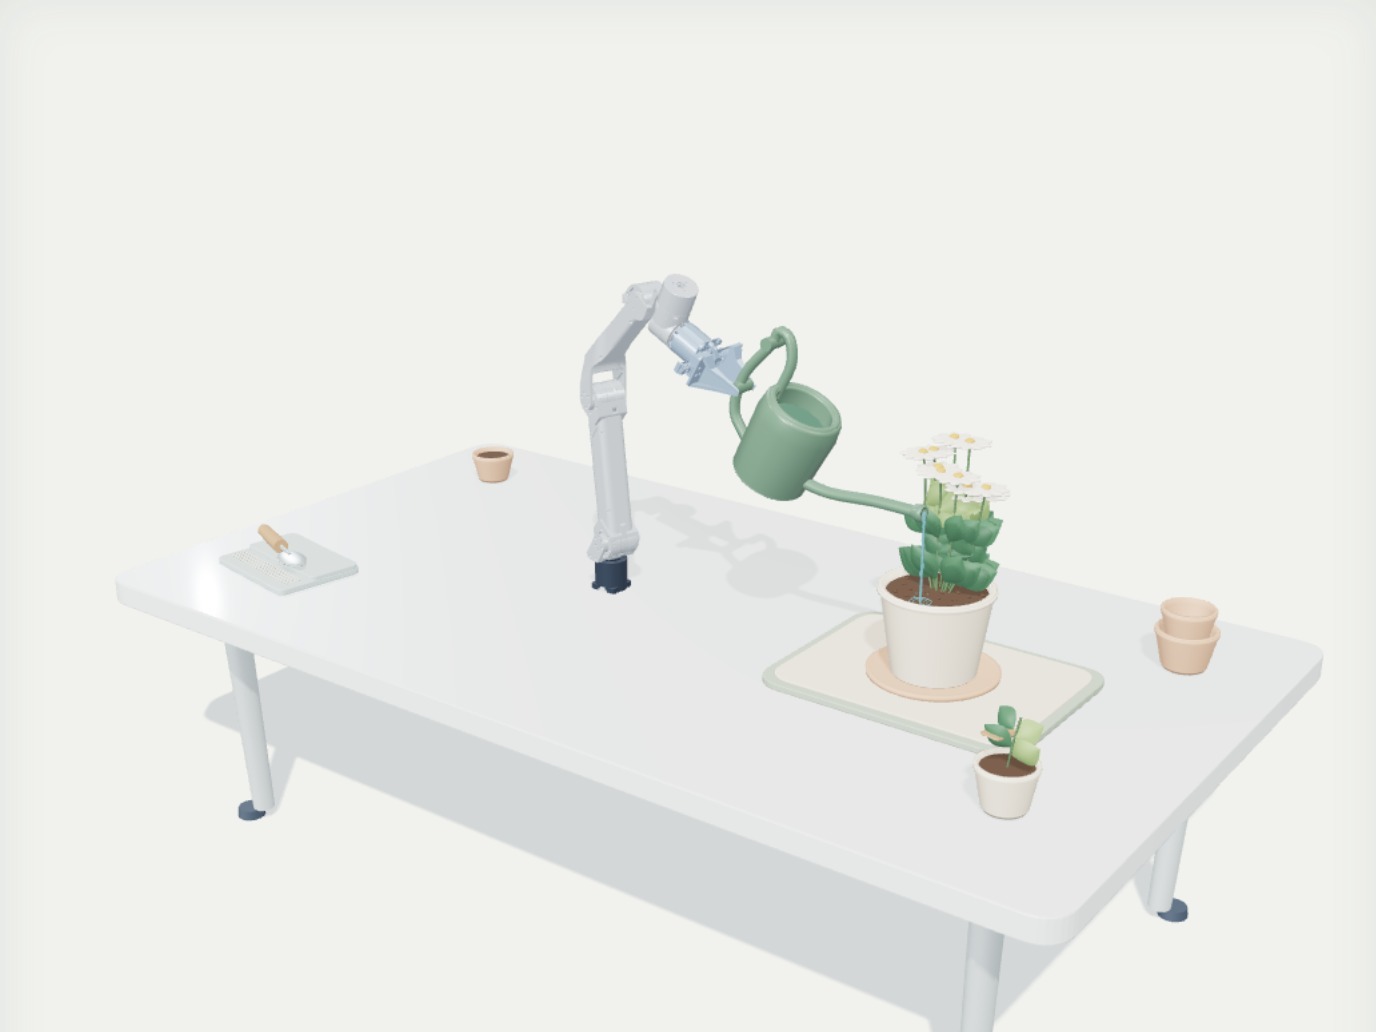
正在载入 ARX5 浇花场景…
ARX5 浇花动作示意
通过 ARX5 浇花场景,呈现机械臂接近花盆、倾倒与收回的动作。
探索统一 API 接入,连接任务指令、环境观测与动作输出,面向多样化机器人本体开展适配。下方展示部分构型示例。
部分构型展示
三维模型需要启用 JavaScript。